Feasibility and Routing
Assembly process group routings consists of Pick and Place followed by Mechanical Assembly, various sealing, fastening, and bonding processes, and/or Welding. Welding (except Ultrasonic Welding) is optionally preceded by Weld Prep and optionally followed by Weld Clean Up.

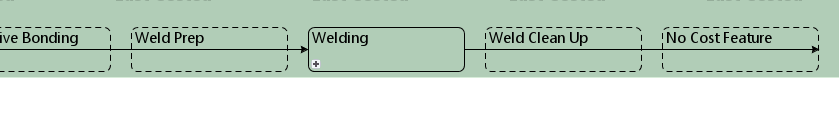
Optional secondary processes include Machining, Surface Treatment, Heat Treatment, and Packaging.
This section contains the following subsections:
Adhesive Bonding Routing
You must manually assign the Adhesive Bonding operation to the ContactRegions to be bonded (see Contact Regions and Contact Groups).
Lock Bolt Routing
You must manually assign the Lock Bolt operation (Lock Bolt Install) to one member of each pair of subcomponents to by joined using a lock bolt.
Threaded Insert Routing
You must manually assign the Threaded Insert operation to one member of each pair of subcomponents to by joined with the help of a threaded insert. (You must separately assign a Screw Tighten operation from the Mechanical Assembly process.)
Sealing Routings
There are three sealing processes, each of which must be manually included in your routing:
-
Cap Sealing: used to seal the contact points of a fastener.
-
Fay Sealing: used to seal flat contact areas between two parts.You must manually assign the Fay Sealing operation to the ContactRegions to be bonded (see Contact Regions and Contact Groups).
-
Fillet Sealing: used to seal flat contact areas between two parts.
Rivet Process Routing
You must manually include the Rivet process in your process routing. This process accounts for the cost of riveting all the assembly's holes that are within a specified size range, or riveting a specified number of holes. You must cost all subcomponents of the assembly before you include this process. Note that you can also rivet a specified subcomponent with the Rivet operation of the Mechanical Assembly process.
Pick and Place Routing
The Pick and Place process is included in all assembly routings. It supports the following operations:
-
Load: performed on each of the assembly's Subcompoment GCDs. Each occurrence of this operation models loading a Subcomponent into the assembly fixture or to a mating Subcomponent already assembled, including bin pick and insertion. The assumed load time and number of loading operators depend by default on the Subcomponent weight and length--see Pick and Place Formulas.
-
Clamping: performed on each ContactGroup GCD with at least one welded ContactRegion (see Part Geometry in Cost Model Overview). If the setup option Clamping Startegy for Welded Subcomponents is set to Clamp twice - once for tacking and once for welding, the operation is performed twice on each such ContactGroup. Otherwise it is performed once on each such ContactGroup (the default in starting point Digital Factories). See Pick and Place Options.
Each occurrence of this operation accounts for the time required to clamp the welded ContactRegions of the ContactGroup in order to prepare the assembly for subsequent welding operations. Each occurrence also accounts for the time required to remove the clamps after welding. The required time depends on the number of clamps applied, which depends on the dimensions of the ContactGroup's welded ContactRegions--see Pick and Place Formulas.
Note that a welded ContactRegion of a given ContactGroup is a ContactRegion for which both the following hold:
-
The ContactRegion bears the Lies On relation to the ContactGroup.
-
Some Weld GCD bears the Lies On relation to the ContactRegion.
-
Mechanical Assembly Routing
You must manually assign Mechanical Assembly operations (such as Nut Insert, Press Fit, or Rivet) to each Subcomponent that requires it. Mechanical Assembly is included in the current routing only if you make at least one such assignment. The Mechanical Assembly process supports the following operations:
-
Nut Insert
-
Press Fit
-
Rivet
-
Screw Tighten – Manual
-
Screw Tighten – Power
-
Snap Fit
-
Tab Bend
Note: In a case where two components are held together with a fastener, a fastening operation only needs to be applied to one of the components. In a case where a bolt, nut, and washer that will be used to secure part of the assembly are modeled, the fastening operation only needs to be applied to one of the components.
Welding Routing
Welding processes (except Ultrasonic Welding) are included in the current routing only if the current assembly contains welds. In many cases you must manually create virtual welds; see Assembly Welds. This applies to eight welding processes:
-
Manual MIG Welding
-
Manual TIG Welding
-
Manual Spot Welding
-
Robotic MIG Welding
-
Robotic TIG Welding
-
Robotic Spot Welding
-
Electron Beam Welding
-
Laser Welding
Each process supports a single welding operation. The characteristics of each weld GCD determine which welds are handled by which process’s operation; see Welding Operation Feasibility.
For the following processes, you must manually assign the corresponding welding operation to each weld that requires it:
-
Manual TIG Welding
-
Robotic TIG Welding
-
Laser Welding
-
Electron Beam Welding
In the Manufacturing Process pane or Geometric Cost Drivers pane, right-click the GCD to which you want to assign the operation, and select Edit Operation. Also note that the Weld GCD’s Production Mechanism field must be set to Robotic for either Laser Welding or Electron Beam operations to cost successfully.
You must manually assign Weld Prep and/or Weld Cleanup operations to each weld that requires them. Weld Prep supports the following operations:
-
Bevel Cutting
-
Grinding
-
Wire Brushing
Weld Clean Up supports the Grinding operation.
Ultrasonic Welding applies only to assemblies whose primary process group is Assembly Plastic Molding Process Group. You must manually assign the Ultrasonic Welding operation to each weld that requires it. In the Manufacturing Process pane or Geometric Cost Drivers pane, right-click the GCD to which you want to assign the operation, and select Edit Operation.
Ultrasonic Welding is preceded by Pick and Place and optionally preceded by one or more of the following:
-
Mechanical Assembly
-
Rivet
-
Threaded Insert
-
Adhesive Bonding
Welding Operation Feasibility
The welding operations have feasibility requirements that are based on the Weld Type and Production Mechanism which were specified in the Welding dialog when the weld was created, or were determined by extraction from the CAD model. Following are the requirements:
-
Manual MIG Welding: both the following must hold:
-
Weld type is not Spot.
-
Production Mechanism is not Robotic.
-
Travel speed data is available (see MIG Welding Operation Weld Time)
-
-
Manual TIG Welding: both the following must hold:
-
Weld type is not Spot.
-
Production Mechanism is not Robotic.
-
-
Manual Spot Welding: both the following must hold:
-
Weld type is Spot.
-
Production Mechanism is not Robotic.
-
-
Robotic MIG Welding: both the following must hold:
-
Weld type is not Spot.
-
Production Mechanism is Robotic.
-
Travel speed data is available (see MIG Welding Operation Weld Time)
-
-
Robotic TIG Welding: both the following must hold:
-
Weld type is not Spot.
-
Production Mechanism is not Robotic.
-
-
Robotic Spot Welding: both the following must hold:
-
Weld type is Spot.
-
Production Mechanism is Robotic.
-
-
Electron Beam Welding: all the following must hold:
-
Weld type is not Spot.
-
Production Mechanism is Robotic.
-
Weld depth does not exceed the value of the cost model variable EBWMaximumWeldDepth (100mm in starting point Digital Factories).
-
-
Laser Welding: all the following must hold:
-
Weld type is not Spot.
-
Production Mechanism is Robotic.
-
Weld depth does not exceed the value of the cost model variable LWMaximumWeldDepth (100mm in starting point Digital Factories).
-
Weld Prep Operation Feasibility
The Weld Prep operation Bevel Cutting is feasible for a given weld only if the Weld Type is not any of the following:
-
Spot
-
Fillet
-
Square Groove
-
Plug
-
Slot
-
Tack
-
Wrap Tie
Material Selection
The processes in this group do not use any material; material cost is always 0 for all processes. Welding wire is considered to be expendable tooling; see MIG Welding Expendable Tooling Calculation and Spot Welding Expendable Tooling Calculation.
Machine Selection
For most processes in this process group, machine selection works as follows (exceptions include Electron Beam Welding and Laser Welding; see below):
-
By default in starting point Digital Factories, the lowest-overhead virtual machine is selected.
-
If the cost model variable preferVirtualMachines is false (it is true in starting point Digital Factories), the lowest-overhead default machine is selected, if there is one.
-
Otherwise, the lowest-overhead machine is selected (regardless of whether it is a virtual machine). You can manually select a non-default machine.
Overhead, here, is given by the sum of the machine properties Direct Overhead Rate and Indirect Overhead Rate.
For Electron Beam and Laser Welding, aPriori selects the feasible machine with the lowest per-part overhead rate.
Overhead rate is given by the sum of the machine properties Direct Overhead Rate and Indirect Overhead Rate. Per-part overhead rate is calculated by amortizing this value over the maximum number of parts that can fit in the machine (considering both lengthwise and widthwise orientations, with space between parts specified by the cost model variable EBWMinPartSpacing or LWMinPartSpacing--50mm in starting point Digital Factories) or over the number of parts specified by the user with the setup option Number of Parts in the Machine per Cycle.
An Electron Beam Welding machine is feasible if both the following hold:
-
Machine can accommodate the weight and dimensions of the part (based on the machine properties Max Weight, Working Height, Working Width, and Working Length).
-
Value of the machine property Is Load Lock Machine matches the value of the setup option Is the EB Welding Machine a Load Lock Machine (false, by default).
A Laser Welding machine is feasible if the machine can accommodate the weight and dimensions of the part (based on the machine properties Max Weight, Working Height, Working Width, and Working Length).
For Electron Beam and Laser Welding, aPriori selects only from virtual machines, if there is a feasible preferred machine and the cost model variable preferVirtualMachines is set to true (the default in starting point Digital Factories). If there is no feasible virtual machine, or if the cost model variable preferVirtualMachines is set to false, aPriori selects the default machine, if it is feasible. Otherwise, aPriori selects from all machines. A machine is virtual if the machine property isVirtualMachine (typically displayed as Is Virtual Machine) is true.
For Ultrasonic Welding, aPriori selects the least expensive, feasible machine. A machine is feasible only if all the following hold:
-
Machine property Table Configuration matches the setup option Machine Table Configuration.
-
Part height is no greater than the Machine property Max Component Height.
-
For rotary machines, machine table size can accommodate the Number of Stations, given the part size.
-
For bench machines, machine table size can accommodate part size (assuming a single station).
-
Machine property Transducer Power is no less than the power required for the longest weld whose Ultrasonic Welding Type is Welding, as listed in the lookup table tblUltrasonicWeldingPowerLength. (See also Length of Ultrasonic Weld.)
-
Machine property Transducer Power is no less than the power required for the widest weld whose Ultrasonic Welding Type is Insertion, as looked up in the lookup table tblUltrasonicWeldingPowerLength.