Slide and Core Bundling for Investment Casting
aPriori analyzes a part’s unthreaded holes and voids in order to determine which, if any, must be handled by a slide or core. For those GCDs that do require a slide or core, aPriori determines which can be grouped together onto a common action. In this way, aPriori can determine the number and size of the slides and cores required for the part’s mold.
Each resulting slide is represented by a GCD with a name such as SlideBundle:1 or SlideBundle:2, and so forth. These GCDs appear in the Geometric Cost Drivers pane under the Slide Bundles, which appear under the Volume node.
Each resulting core is represented by a GCD with a name such as CoreBundle:1 or CoreBundle:2, and so forth. These GCDs appear in the Geometric Cost Drivers pane under the Core Bundles, which appear under the Volume node.
By default, a hole, ring, combo void, or void is assumed to require a slide or core if it satisfies all the following conditions:
Machining isn’t manually assigned for this GCD.
Manufacturability property of hole or ring is equal to CAST or CAST_AND_MACHINED.
Void is large enough to be cast.
One of the following conditions holds:
Hole, combovoid, or void is non-shellable,that is, the isShelled property of the GCD is set to false.
GCD is obscured, that is, it is not accessible from the draw direction.
GCD is self-obstructed (as with, for example, a Multi Step Hole with three child Simple Holes where the middle Simple Hole has the largest diameter).
(Users of the Cost Model Workbench can customize these conditions by modifying the CSL in mcdBundleCandidateRule.csl on the branch node Component > Casting - Investment.)
For SimpleHoles, MultiStepHoles, Rings, Voids, and ComboVoids, you can apply a GCD-specific override, and specify that a feature does not require a slide or a core.
Follow these steps to specify that a feature does not require a side action:
Click the GCD either in the Component Viewer or the Geometric Cost Drivers pane.
Double click the Property Result field for the property Excluded From Bundling and select true.
Re-cost the scenario.
This section has the following subsections:
Slide Bundling Criteria
A group of GCDs can form a bundle and be handled by a single slide only if none of them is self-obstructed, they are all shell-able (the value of the geometric property Is Shelled is true for each), and there is a direction, D, (represented by a SetupAxis) such that all the following hold:
All the GCDs are accessible from D.
D is sufficiently close to orthogonal to the draw direction.
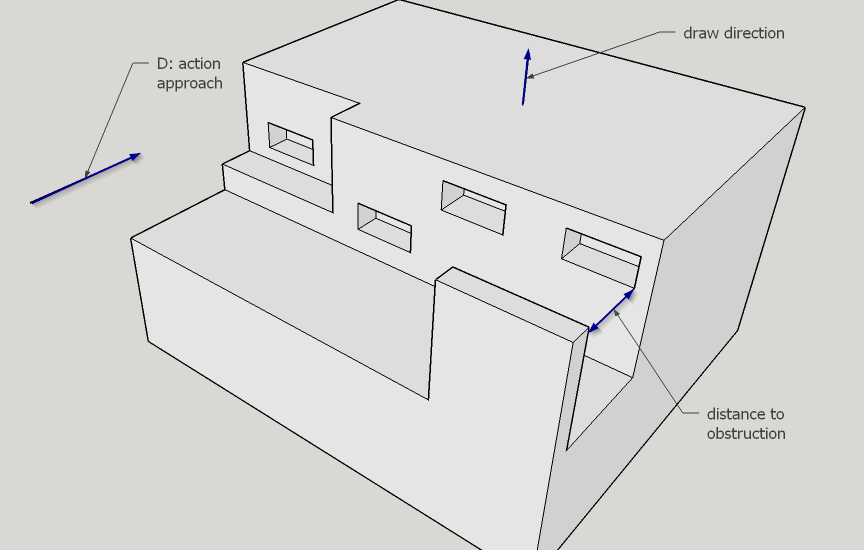
For each GCD, if access to the GCD from D is obstructed, the obstruction is sufficiently far from the GCD.
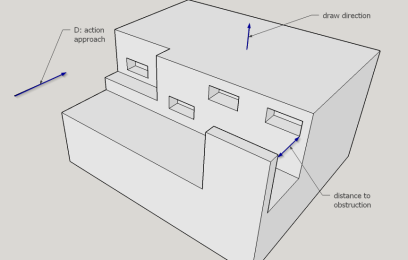
The cost model variable minimumSlideClearance specifies the threshold for being sufficiently far; this value is 196.75mm in aPriori starting point Digital Factories.
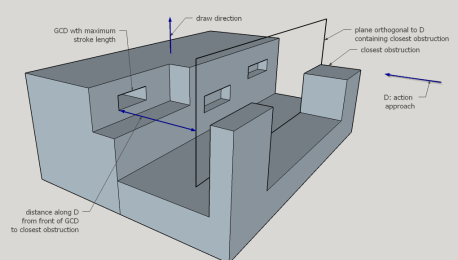
The distance between the GCD and the obstruction is the Distance to Obstruction property of the Is Accessible From relation whose value for First is the GCD and whose value for Second is the SetupAxis that represents D.
All GCDs can be manufactured by a slide that does not obstruct any volume beneath the slide. The faces under a slide must not form any kind of hook; otherwise, the slide would not be pullable. That is, for each GCD the Has Blocked Volume property of the Is Accessible From relation whose value for First is the GCD and whose value for Second is the SetupAxis that represents D is equal to false.
Any two adjacent GCDs are sufficiently close (in the direction orthogonal to both D and the draw direction).
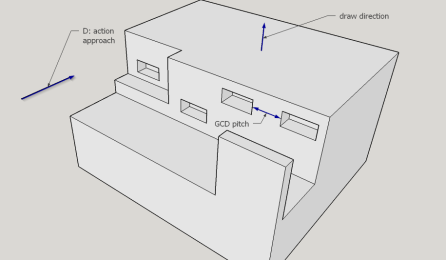
The cost model variable maxGcdPitch specifies the threshold for being sufficiently close; this value is 50.8mm in aPriori starting point Digital Factories.

For any two adjacent GCDs that do not share the same volume, the distance between them along direction D is sufficiently small.
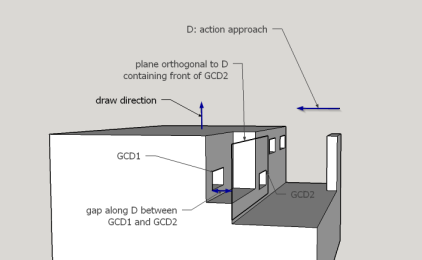
The cost model variable maxSlideDepthPitch specifies the threshold for being sufficiently small; this value is 25.4mm in aPriori starting point Digital Factories.
The distance measured is between the GCD fronts (that is, the side of the GCDs on which the slide enters).

Each GCD is sufficiently close to the part edge. That is, for each GCD, the distance from the GCD along D to the part edge is sufficiently small.
The cost model variable maxGcdDistanceFromPartEdge specifies the threshold for being sufficiently small; this value is 25.4mm in aPriori starting point Digital Factories.
There is an exception when the slide is behind another slide (that is, there is a line in direction D that intersects both the slide under consideration and some other slide closer to the part edge). In such a case, distance to part edge is ignored.
Distance to part edge is the value of the Distance to Shadow Border property of the Is Accessible From relation whose value for First is the GCD and whose value for Second is the SetupAxis that represents D.
GCDs have sufficient clearance to accommodate the slide’s stroke length and avoid die lock. That is, the depth (along D) of the deepest GCD (plus some extra depth for the action base) is less than the smallest distance between a GCD and the obstruction that is closest to its associated GCD.
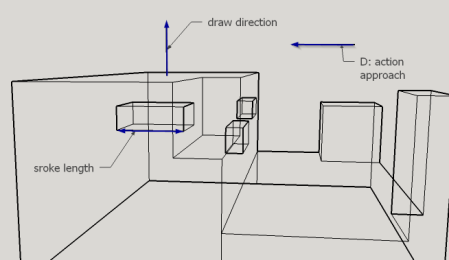


The slide is not too long (in the direction orthogonal to both D and the draw direction).
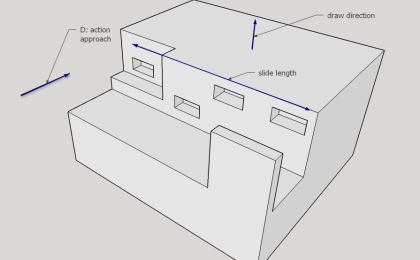
The cost model variable maxActionLength specifies the threshold for being too long; this value is 500mm in aPriori starting point Digital Factories.
Slide length is the total GCD span in the direction orthogonal to both D and the draw direction.

Core Bundling Criteria
A group of GCDs can form a bundle and be handled by a single core only if none are self-obstructed and there is a direction, D, (represented by a SetupAxis) such that all the following hold:
All the GCDs are accessible from D.
D is not parallel to the draw direction.
All the GCDs have enough clearance to avoid tool die lock.
Any two adjacent GCDs are sufficiently close in two directions: in the direction, A, orthogonal to both D and the draw direction, and in the direction orthogonal to both D and A.
The cost model variable maxGcdPitch specifies the threshold for being sufficiently close; this value is 50.8mm in aPriori starting point VPEs.
For any two adjacent GCDs that do not share the same volume, the distance between them along direction D is sufficiently small.
The cost model variable maxCoreDepthPitch specifies the threshold for being sufficiently small; this value is 25.4mm in aPriori starting point VPEs.
The distance measured is between the GCD fronts (that is, the side of the GCDs on which the slide enters).
The core is not too long (in the direction orthogonal to both D and the draw direction).
The cost model variable maxActionLength specifies the threshold for being too long; this value is 500mm in aPriori starting point VPEs.
Core length is the total GCD span in the direction orthogonal to both D and the draw direction.
Further Bundling Criteria—Breaking Ties
If a GCD group can be handled by multiple slides or by a single core, aPriori prefers creation of multiple slides.
If multiple directions of access are appropriate for a bundle, aPriori prefers the direction that provides the smaller tool length.
If multiple directions of access providing the same tool length are appropriate for a bundle, aPriori prefers the direction that provides the smaller distance to the part edge.
If some GCD can be handled by multiple different actions of the same type, it is bundled to minimize the maximal width/depth gap between GCDs in each action and minimize interference with holes that don’t belong to the bundle.
If some GCD is not bundled for any of action types, a single core with no setup axis assigned is created for this GCD.